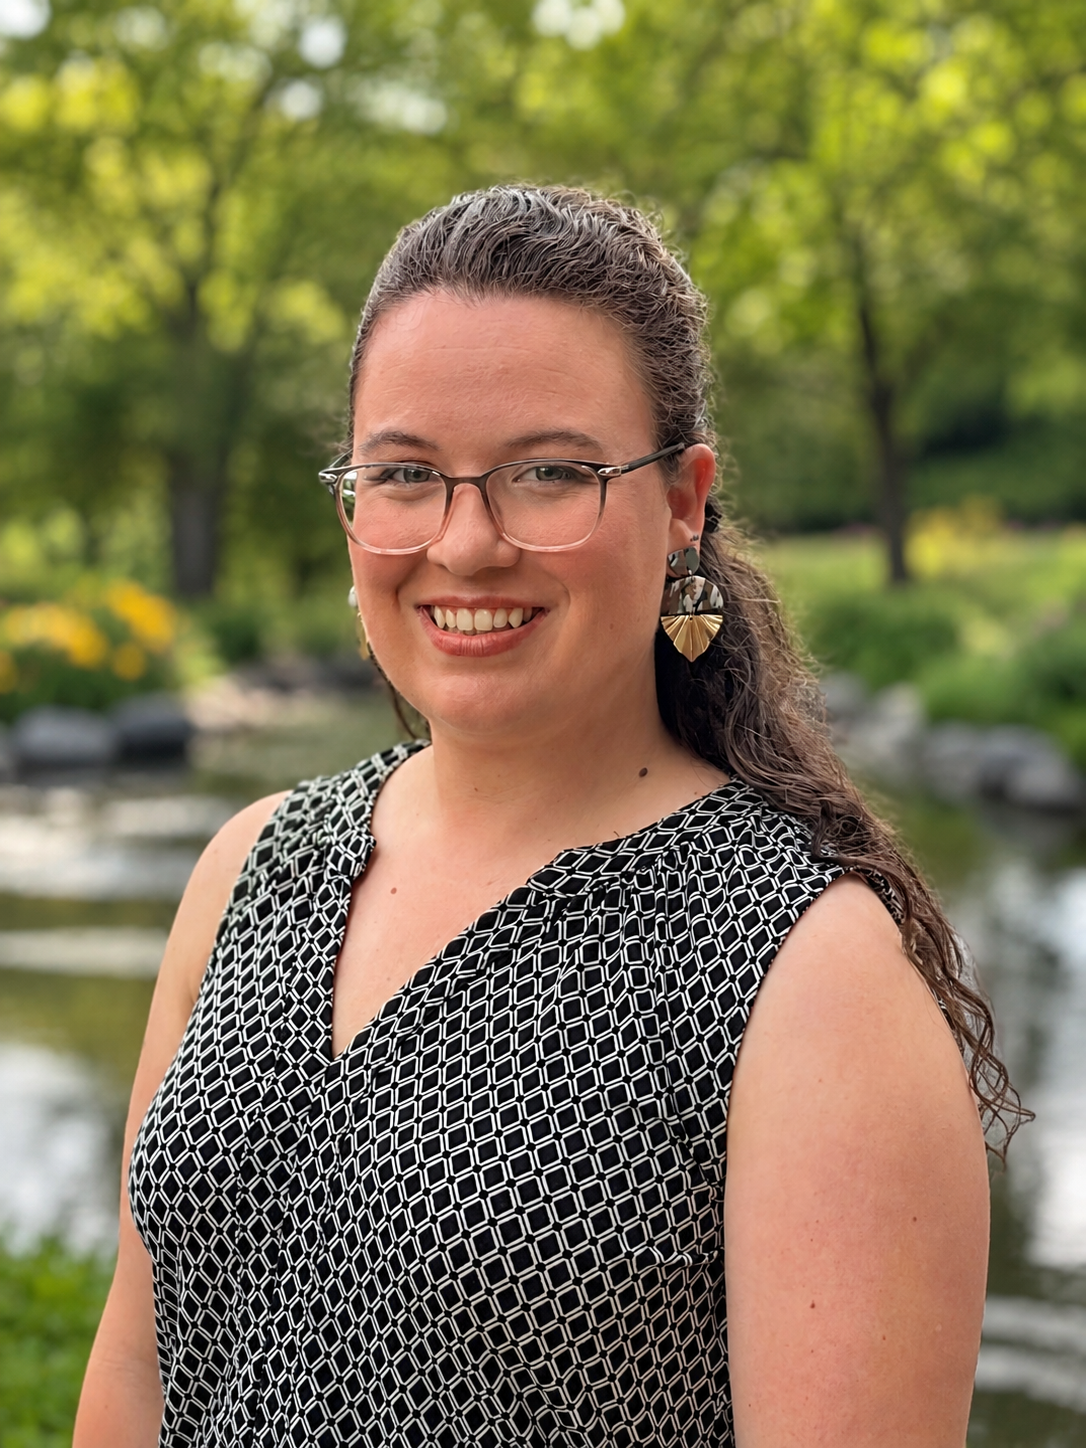
Victoria Tuck
Multi-Agent Systems · Postdoctoral Researcher · University of Pennsylvania
As autonomous systems move from single agents in controlled settings into critical infrastructure, dependable operation under uncertainty and competing incentives becomes both essential and difficult. My research develops algorithmic frameworks with theoretical guarantees for multi-agent cyber-physical systems in these settings. Specifically, I design for safety under uncertainty; efficient, sustained coordination; and social alignment among self-interested agents,. Applications of my work include next-generation air mobility and multi-robot systems. More broadly, my long-term vision is to make the design of large-scale multi-agent systems as principled and routine as modern software engineering.
I am on the 2026-2027 faculty job market.
About
I am currently a Postdoc at the University of Pennsylvania advised by George Pappas. Previously, I completed my Ph.D. at UC Berkeley in Electrical Engineering and Computer Sciences advised by Shankar Sastry and Sanjit Seshia. Before and during my Ph.D., I interned with Zipline, Toyota, and Sandia National Labs. I received my B.S. and M.S. from Georgia Tech (Go Jackets!). My teaching efforts have been recognized with both the Berkeley EECS department and campus Outstanding Student Instructor awards. As an advocate for increased diversity in engineering, I have partnered with groups such as Community Resources for Science and the Girl Scouts on efforts to improve science education in schools and promote girls and women in STEM. In my personal time, I enjoy singing with the Mendelssohn Chorus of Philadelphia and painting.
News
Publications
* denotes equal contribution.
Journal Articles
Resilient Decentralized Ergodic Coverage for Scalable Multi-Robot Systems in Unknown Time-Varying Environmentsunder review
Maria G. Mendoza, Victoria M. Tuck, Chinmay Maheshwari, S. Shankar Sastry · 2026 · arXiv:2604.04280
Privacy-Preserving Mechanisms for Coordinating Airspace Usage in Advanced Air Mobility
Chinmay Maheshwari*, Maria G. Mendoza*, Victoria M. Tuck*, Pan-Yang Su, Victor Qin, Sanjit A. Seshia, Hamsa Balakrishnan, S. Shankar Sastry · ACM J. Auton. Transport. Syst. (JATS) · 2025
Conference Papers
Time-To-Reach Separation and Safety Filtering for Safe, Fair, and Efficient Multi-Agent Coordination
Matthew Low, Jasmine J. Aloor, Victoria M. Tuck, Pierluigi Nuzzo, Jason J. Choi · 64th IEEE Conference on Decision and Control (CDC) · 2026 (to appear) · arXiv:2605.20625
Incentive-Compatible Vertiport Reservation in Advanced Air Mobility: An Auction-Based Approach
Pan-Yang Su*, Chinmay Maheshwari*, Victoria M. Tuck, S. Shankar Sastry · 63rd IEEE Conference on Decision and Control (CDC) · 2024
SMT-Based Dynamic Multi-Robot Task Allocation
Victoria M. Tuck, Pei-Wei Chen, Georgios Fainekos, Bardh Hoxha, Hideki Okamoto, S. Shankar Sastry, Sanjit A. Seshia · NASA Formal Methods Symposium (NFM) · 2024
DEC-LOS-RRT: Decentralized Path Planning for Multi-Robot Systems with Line-of-Sight Constrained Communication
Victoria M. Tuck, Yash V. Pant, Sanjit A. Seshia, S. Shankar Sastry · IEEE Conference on Control Technology and Applications (CCTA) · 2021
Preprints
MRTA-Sim: A Modular Simulator for Multi-Robot Allocation, Planning, and Control in Open-World Environments
Victoria M. Tuck, Hardik Parwana, Pei-Wei Chen, Georgios Fainekos, Bardh Hoxha, Hideki Okamoto, S. Shankar Sastry, Sanjit A. Seshia · 2025 · arxiv:2504.15418
Teaching
Embedded Systems (UG/Grad), UC Berkeley
Graduate Linear Controls (Grad), Georgia Tech
Undergraduate Microelectronics Lab (UG), Georgia Tech
MATLAB for Engineers (UG), Georgia Tech